How to Prevent UAV Video and Telemetry Link Failures Using Dual-Radio Wi-Fi 6
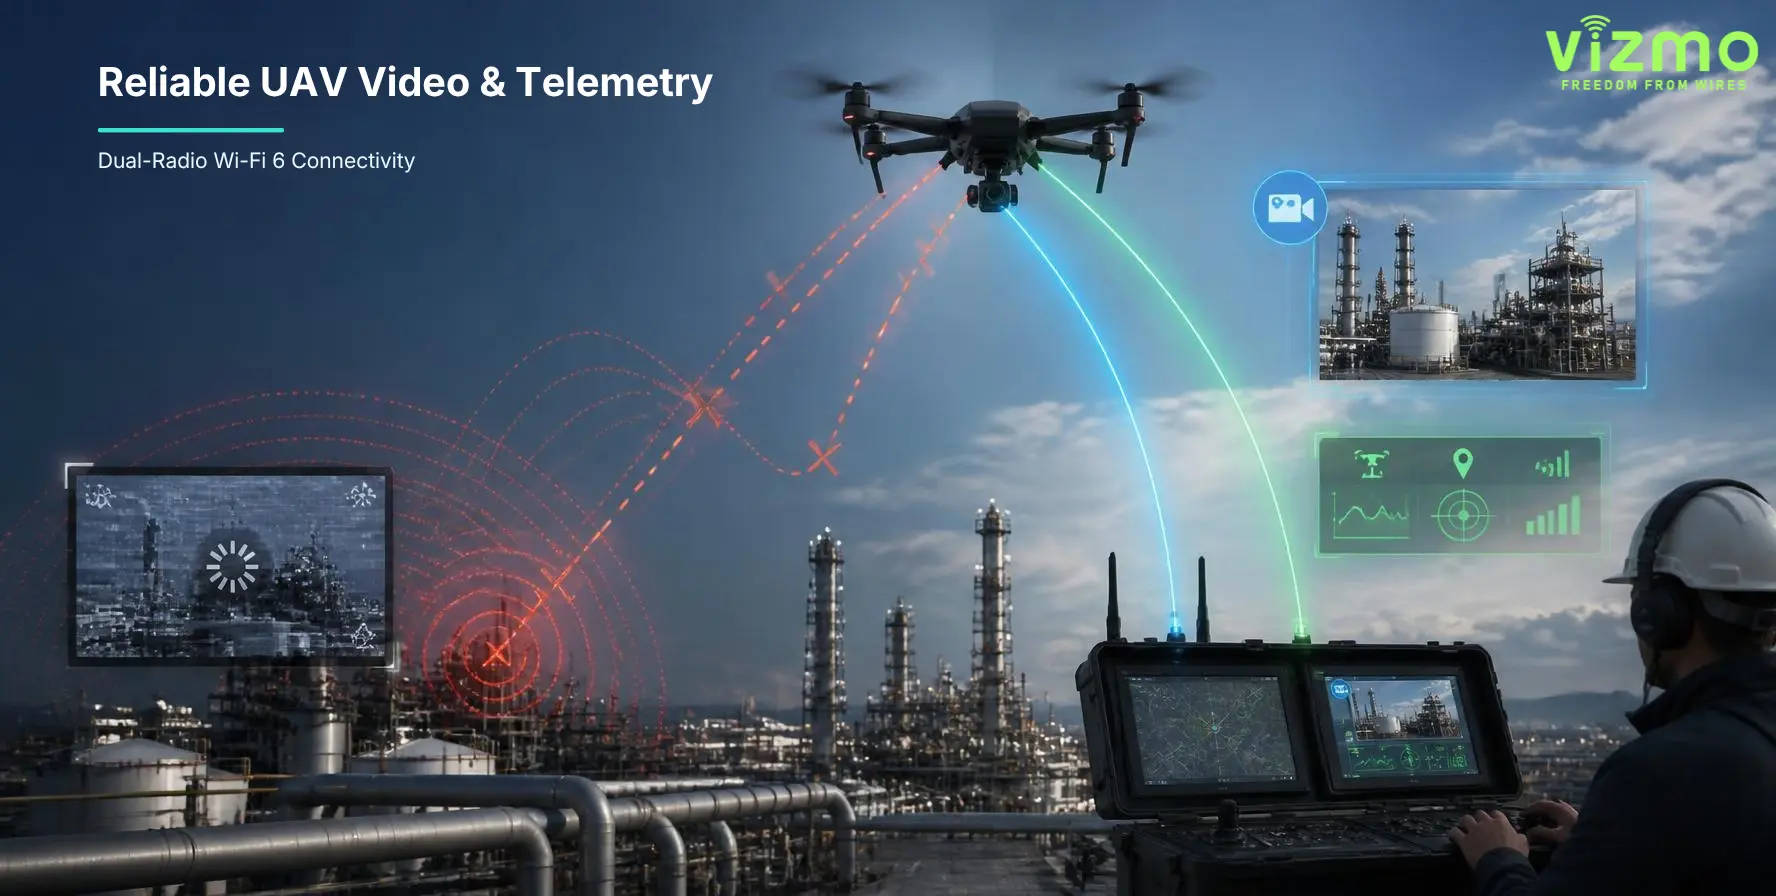
During an industrial drone inspection, the ground control station may continue receiving the aircraft’s position, altitude, and battery status while the live video feed suddenly freezes. The drone remains connected, but the operator can no longer see what the camera is capturing.
This situation is particularly challenging during infrastructure inspections, emergency response missions, and remote asset monitoring, where operators depend on timely visual information.
The problem is not always caused by insufficient wireless range. Video transmission and telemetry place different demands on a communication network. Interference, limited bandwidth, packet retransmissions, antenna orientation, and network congestion can affect each data stream differently.
For Unmanned Aerial System (UAS) manufacturers, the challenge is to design wireless connectivity that supports both continuous video and dependable operational data without allowing one application to overwhelm the other.
A dual-radio Wi-Fi 6 architecture offers one way to address these requirements. By using independent radio interfaces, engineers can separate traffic, manage wireless capacity, and select operating frequencies according to the mission.
This article explains how to identify UAV communication problems, evaluate dual-radio networking, and apply the technical capabilities of Vizmonet’s BlackPepper 6 BKP6-AX2AX2-2450 in an embedded UAV communication design.
Why Do UAV Video and Telemetry Links Become Unstable?
A UAV communication system typically carries several types of data between the aircraft and its ground infrastructure.
Telemetry includes flight status, position, altitude, battery information, and other operating parameters. These messages are generally small and require comparatively little bandwidth, although timely and dependable delivery remains important.
Live video has different requirements.
A camera continuously captures images, which are encoded, transmitted through the wireless network, received, decoded, and displayed at the ground station. Higher video resolution, frame rates, and additional camera feeds increase the amount of data the network must carry.
When video and telemetry share a constrained wireless link, the resulting traffic can compete for available airtime.
For example, an inspection UAV may have enough bandwidth to transmit telemetry during takeoff. Once the onboard inspection camera begins streaming, network utilization increases. If signal quality deteriorates or interference causes retransmissions, the effective wireless capacity may fall below what the video application requires.
The video feed may freeze even while telemetry continues arriving.
This happens because maintaining a wireless connection and delivering sufficient application throughput are two different things.
A UAV radio can remain associated with its ground station while no longer supporting the required video bitrate or latency.
The first step toward improving reliability is understanding which part of the communication path is failing.
Five Common Causes of UAV Video and Telemetry Link Failures
1. RF Interference and Wireless Channel Congestion
Industrial UAVs often operate near existing wireless infrastructure.
Factories, ports, construction sites, and energy facilities may contain Wi-Fi equipment, wireless sensors, surveillance networks, and industrial communication systems.
When several wireless devices compete for the same channel, transmission delays and packet retransmissions can increase.
A UAV may maintain a strong received signal but still experience poor application performance because the channel is congested.
Increasing transmitter power will not necessarily solve this problem. Engineers need to understand channel utilization, interference, signal-to-noise ratio, and the behavior of surrounding wireless systems.
2. Video Traffic Exceeding Available Throughput
Wireless specifications often highlight maximum data rates under favorable conditions.
However, actual application throughput is lower than the physical-layer data rate because wireless communication includes protocol overhead, management traffic, acknowledgments, and sometimes retransmissions.
As a UAV moves away from its ground station or encounters less favorable RF conditions, its available throughput may decrease.
If the camera encoder continues producing more data than the link can carry, packets can accumulate in buffers or be dropped.
The result may be delayed video, dropped frames, or a frozen display.
3. Aircraft Movement and Antenna Orientation
A UAV rarely maintains one fixed position relative to its ground station.
It climbs, turns, banks, and changes direction throughout a mission.
These movements alter the orientation of its antennas. Batteries, motors, carbon-fiber structures, and payload enclosures can also affect radio propagation.
A configuration that performs well during stationary ground testing may behave differently once installed in a moving aircraft.
4. Packet Retransmissions and Network Delays
Wireless links recover from some transmission errors by retransmitting packets.
This can improve successful delivery, but repeated transmissions consume airtime and increase delay.
Live video is particularly sensitive to excessive latency and jitter.
A system may report acceptable average throughput while the ground station still experiences irregular frame delivery.
5. Shared Network Resources
Video, telemetry, sensor data, and software services may compete for resources beyond the wireless channel.
Potential bottlenecks include the onboard processor, video encoder, network queues, and ground-station decoder.
For that reason, replacing a radio should not be the first troubleshooting action.
Engineers should identify whether the failure starts in the camera system, processing hardware, IP network, RF link, or receiving application.
How to Identify the Actual Cause of UAV Communication Failures
A structured diagnosis helps avoid unnecessary hardware changes.
The following troubleshooting matrix provides a starting point.
| Observed problem | Possible cause | Recommended engineering check |
|---|---|---|
| Telemetry works, but video freezes | Video bandwidth limitation, packet loss, or encoding delays | Measure video bitrate, sustained throughput, packet loss, and buffering |
| Video becomes unstable during UAV turns | Antenna orientation or airframe shadowing | Compare RSSI and SNR at different aircraft orientations |
| Strong signal but poor video performance | Channel congestion or interference | Measure channel utilization and retransmissions |
| Latency increases when sensors activate | Shared network or processing resources | Monitor traffic load, network queues, and processor utilization |
| Both communication paths fail together | Shared power, software, or interference problem | Inspect common dependencies and system logs |
| Performance deteriorates during extended operation | Potential thermal or electrical instability | Monitor module temperature and supply voltage |
Begin by reproducing the failure under controlled conditions.
Check the camera and encoder locally before investigating the RF link. Then record network traffic, received signal quality, retransmission statistics, and application latency.
Change one parameter at a time. This makes it easier to identify whether an adjustment actually improves performance.
For a more detailed explanation of the measurements involved, read Vizmonet’s guide to radio performance metrics, range, and throughput.
How Dual-Radio Wi-Fi 6 Helps Manage UAV Communication Traffic
A conventional single-radio architecture carries multiple applications through one wireless interface.
This approach can work well for UAVs with modest data requirements or carefully managed traffic.
However, continuous video streaming and additional sensor payloads can create more demanding network conditions.
A dual-independent-radio architecture offers greater flexibility by allowing different traffic types to use separate wireless interfaces.
For example:
| Radio interface | Proposed application | Primary requirement |
|---|---|---|
| Radio 1 — 2.4 GHz | Telemetry and selected operational data | Consistent message delivery |
| Radio 2 — 5 GHz | Live video and high-bandwidth payload data | Sustained throughput and controlled jitter |
This is an example architecture. The final frequency assignment depends on operating conditions, permitted spectrum, software configuration, and the intended mission.
What Makes Independent Radios Different from Ordinary Dual-Band Wi-Fi?
Some dual-band Wi-Fi equipment supports both 2.4 GHz and 5 GHz but uses a single radio that operates on one band at a time.
A dual-independent-radio design provides distinct radio interfaces capable of operating simultaneously.
That distinction matters when engineers want to separate communication traffic.
Instead of carrying all applications through one wireless channel, the system can allocate different data streams to different radio interfaces.
When appropriately configured, this can reduce direct airtime competition between the traffic paths and provide greater flexibility for RF channel planning.
However, two independent radios do not automatically create a redundant communication system.
Automatic failover, routing policies, network recovery, and application-level safety mechanisms must be separately designed and validated.
BlackPepper 6: Dual-Independent Wi-Fi 6 for Embedded UAV Systems
Vizmonet’s BlackPepper 6 BKP6-AX2AX2-2450 is an industrial embedded wireless platform designed for OEM applications.
According to the datasheet, the module combines two independent 2×2 MU-MIMO radio paths supporting 2.4 GHz and 4.9/5 GHz operation.
For UAV system developers, this makes BlackPepper 6 relevant when evaluating separate wireless interfaces for video, telemetry, and other IP-based data.
BlackPepper 6 Technical Specifications
| Parameter | BKP6-AX2AX2-2450 specification |
|---|---|
| Wireless standards | IEEE 802.11 a/b/g/n/ac/ax |
| Radio architecture | Dual-independent 2×2 MU-MIMO |
| 2.4 GHz operating range | 2400–2483.5 MHz |
| 4.9/5 GHz operating range | 4900–5850 MHz |
| Transmit power | Up to 30 dBm, as stated in ordering specifications |
| Processor | Qualcomm IPQ6028, Quad Arm Cortex-A53, 1.8 GHz |
| Ethernet PHY | QCA8081 |
| Operating system | Linux / OpenWrt, ath11k driver support |
| Channel bandwidth — 2.4/4.9 GHz | 5, 10, 20, 40 MHz |
| Channel bandwidth — 5 GHz | 5, 10, 20, 40, 80 MHz |
| Antenna connectors | Four SMA female connectors |
| Input voltage | 9–30 V DC |
| Published DC power consumption | 21 W, excluding USB add-on |
| Operating temperature | −40°C to +85°C |
| Dimensions | 90 × 50 × 11.4 mm, excluding SMA connectors |
| Module weight | 100 g |
These specifications describe the hardware platform. Actual application throughput, communication distance, latency, and system reliability depend on the complete network design.
The module’s maximum stated transmit power should also be distinguished from the mode-specific transmit-power values shown in its RF performance tables.
View the BlackPepper 6 BKP6-AX2AX2-2450 Datasheet
What the BlackPepper 6 RF Specifications Tell UAV Engineers
One of the most useful parts of the BlackPepper 6 datasheet is its detailed transmit-power and receiver-sensitivity information.
These figures help engineers understand why a wireless connection can remain active while its capacity for demanding applications changes.
Receiver Sensitivity and Wi-Fi 6 Modulation
Wi-Fi 6 supports different modulation and coding schemes, commonly identified as MCS levels.
Lower MCS levels generally provide more robust communication under weaker signal conditions, but support lower data rates.
Higher MCS levels allow greater data rates when the received signal has sufficient quality.
The BlackPepper 6 datasheet provides the following examples.
| Frequency profile | Wi-Fi 6 mode | TX power | RX sensitivity |
|---|---|---|---|
| 2.4 GHz | HE20-MCS0 | 27 dBm | −94 dBm |
| 2.4 GHz | HE20-MCS11 | 21 dBm | −67 dBm |
| 4.9/5 GHz | HE20-MCS0 | 27 dBm | −93 dBm |
| 4.9/5 GHz | HE20-MCS11 | 18 dBm | −65 dBm |
| 4.9/5 GHz | HE80-MCS0 | 27 dBm | −87 dBm |
| 4.9/5 GHz | HE80-MCS11 | 18 dBm | −59 dBm |
Values represent specific test modes, not guaranteed in-flight throughput or communication range.
Why This Matters for UAV Video Transmission
Consider the 4.9/5 GHz HE20 operating mode.
The datasheet specifies receiver sensitivity of −93 dBm for HE20-MCS0 and −65 dBm for HE20-MCS11.
The higher MCS profile requires a substantially stronger received signal.
As the aircraft moves farther away, changes orientation, or encounters additional signal loss, the radio may need to operate at a more robust, lower-rate modulation and coding scheme.
A telemetry application with modest bandwidth requirements may continue working.
A video stream configured for a higher sustained bitrate, however, may begin to accumulate delay or drop packets when usable network capacity decreases.
This is why engineers should evaluate receiver sensitivity, selected MCS, and actual application throughput together, rather than relying solely on a maximum wireless data-rate claim.
Channel Width Also Affects Link Planning
The datasheet lists channel widths up to 40 MHz for 2.4 GHz and 4.9 GHz operation, and up to 80 MHz for 5 GHz operation.
A wider channel can provide higher potential capacity, but it also requires consideration of noise, interference, and the available spectrum.
In congested environments, a narrower channel may deliver more consistent performance.
The best configuration is the one that meets the application requirement across expected operating conditions, not necessarily the widest available channel.
How to Estimate a UAV Wireless Link Budget
Before selecting a transmission distance or channel configuration, engineers should estimate the signal level expected at the receiver.
A basic RF link budget accounts for:
- Transmitter output power
- Transmitting antenna gain
- Receiving antenna gain
- Cable and connector losses
- Propagation path loss
- Additional environmental and installation losses
The simplified relationship is:
Received Power (dBm) = TX Power + TX Antenna Gain + RX Antenna Gain − TX Cable Loss − RX Cable Loss − Path Loss
Worked Example: A 5 GHz UAV Link
Consider an illustrative 1 km line-of-sight link using the BlackPepper 6 HE20-MCS0 transmit-power specification.
| Parameter | Example value |
|---|---|
| Transmit power | 27 dBm |
| Transmitting antenna gain | 3 dBi |
| Receiving antenna gain | 3 dBi |
| TX cable and connector loss | 1 dB |
| RX cable and connector loss | 1 dB |
| Approximate free-space path loss at 5 GHz over 1 km | 106.4 dB |
| Calculated received power | −75.4 dBm |
The corresponding HE20-MCS0 receiver sensitivity in the datasheet is −93 dBm.
The simplified calculation therefore places the predicted received signal approximately 17.6 dB above that sensitivity level.
This is an illustrative calculation, not a measured UAV range or performance result.
It excludes aircraft orientation losses, fading, interference, additional implementation losses, and other real-world effects. Regulatory EIRP restrictions must also be applied.
A positive link margin does not establish acceptable video throughput, latency, or flight safety.
For early-stage planning, OEM engineers can use Vizmonet’s RF Link Planner to evaluate different radio and antenna configurations.
The calculated results should then be compared with measured performance on the completed aircraft.
How to Integrate BlackPepper 6 into a UAV Communication Architecture
Consider a UAV carrying a flight controller, companion computer, inspection camera, and onboard sensors.
The ground infrastructure includes a ground control application, video receiver, and compatible wireless network equipment.
A proposed dual-radio design could work as follows.
Radio Path 1: Telemetry and Operational Data
Selected telemetry messages are passed from the flight-control system through the appropriate onboard software interface.
The companion computer or networking software routes this traffic over the designated wireless network.
In one possible configuration, the 2.4 GHz radio carries telemetry and selected operational information.
Its performance requirements are defined around message delivery, latency, and recovery behavior rather than high video throughput.
Radio Path 2: Video and Payload Data
The camera sends video to an encoder or companion computer.
The encoded stream is transmitted over the second radio interface toward a compatible ground-side receiver.
A permitted 5 GHz channel may be evaluated for the high-bandwidth video path.
This separation allows the engineering team to configure and test the two traffic paths independently.
Both the airborne equipment and ground station must support the intended interface, network, and routing configuration.
Documented Antenna Assignments
The BlackPepper 6 features four SMA connectors.
| Connector | Radio assignment |
|---|---|
| SMA 1 | 4.9/5 GHz — Antenna 1 |
| SMA 2 | 4.9/5 GHz — Antenna 2 |
| SMA 3 | 2.4 GHz — Antenna 1 |
| SMA 4 | 2.4 GHz — Antenna 2 |
These dedicated antenna connections are useful when planning the radio installation and evaluating simultaneous-radio behavior.
The final antenna installation should consider radiation patterns, polarization, isolation, cable routing, and the UAV’s mechanical structure.
Host and Peripheral Interfaces
The product datasheet also identifies:
- Hirose IX60G-A-10P Ethernet connector
- USB Type-A connector for USB 2.0
- USB Type-C connector for USB 3.0
- Micro-USB connector for UART
- JST connector for E-JTAG
- SD card interface
These interfaces provide options for embedded system integration, depending on the supported software and hardware configuration.
The module does not establish a direct plug-and-play connection to every flight controller. OEMs must verify electrical compatibility, software integration, and the required communication protocols.
Linux and OpenWrt support can be useful for applications requiring configurable IP networking, routing, traffic management, and diagnostic tools.
For a broader overview of connected aerial platforms, see Vizmonet’s Unmanned Aerial Systems applications.
Antenna Placement, Power, and SWaP-C Considerations for UAV OEMs
Wireless performance can change considerably after a module is installed inside an aircraft.
UAV designers must account for size, weight, power, cost, and the physical environment surrounding the radio.
Antenna Placement and Isolation
The two radio interfaces should be evaluated with antennas appropriate to their operating frequencies.
Their placement must consider:
- Aircraft structure and conductive materials
- Antenna radiation patterns
- Polarization changes during flight
- Cable length and insertion loss
- Coupling between nearby antennas
- Interference from onboard electrical equipment
Engineers should test performance while both radios are active.
Independent radio circuitry does not eliminate the possibility of interference or receiver desensitization caused by poor system integration.
Electrical Power Requirements
BlackPepper 6 operates from a 9–30 V DC supply.
The datasheet lists total DC power consumption as 21 W, excluding the USB add-on.
This figure should be included in preliminary UAV power-system planning.
OEMs should also assess voltage stability during changing aircraft loads and determine whether the power distribution system can support the required operating conditions.
The datasheet’s RF tables provide additional mode-specific power-consumption figures, but these should not be substituted for a complete electrical-power evaluation.
Mechanical and Thermal Integration
The BlackPepper 6 module measures 90 × 50 × 11.4 mm, excluding SMA connectors, and has a published weight of 100 g.
The mechanical design includes four M3 mounting points, and the datasheet identifies additional heatsink options. The operating-temperature specification extends from −40°C to +85°C.
These characteristics can be relevant to industrial UAV integration, but operating-temperature capability does not eliminate the need for thermal testing.
Airflow, enclosure design, nearby electronics, continuous radio activity, and ambient conditions all influence the completed system.
The final assembly should be evaluated for mechanical stability, heat dissipation, cable retention, and vibration behavior.
UAV Wireless Link Testing: From Laboratory to Field
A reliable communication design should be validated in stages.
Each stage should produce measurements that engineers can compare against defined application requirements.
Stage 1: Establish a Baseline
Begin with the radio, compatible receiver, and network applications in a controlled environment.
Record the selected frequency, channel width, MCS, transmit-power configuration, RSSI, SNR, throughput, latency, and packet loss.
Verify that both radio interfaces operate as intended.
Stage 2: Test Video and Telemetry Together
Run the expected video and telemetry applications simultaneously.
Measure sustained application throughput, end-to-end delay, jitter, and packet loss.
Compare the results against single-radio operation where an equivalent configuration is available.
This determines whether traffic separation provides a measurable benefit.
Stage 3: Introduce Controlled RF Degradation
Evaluate performance under progressively less favorable RF conditions.
Observe whether the selected MCS changes and how application throughput responds.
Check whether video degrades before telemetry and whether the software responds appropriately.
Stage 4: Test Antenna Orientation
Install the antennas in their intended locations and repeat testing across representative aircraft orientations.
This helps identify airframe shadowing, antenna nulls, and other installation effects that may not appear during bench testing.
Stage 5: Validate Power and Thermal Behavior
Operate the wireless system under sustained traffic.
Record supply voltage, current draw, temperature, and operating stability.
Repeat testing with other aircraft electronics active.
Stage 6: Test Link Loss and Recovery
Assess how the application behaves if one radio link degrades or disconnects.
Verify how the software detects the event and whether traffic is recovered, rerouted, or stopped as designed.
A dual-radio module does not independently guarantee failover. Any required recovery function must be implemented within the wider system.
Engineering Validation Checklist
| Test condition | Measurement | Acceptance criterion |
|---|---|---|
| Normal flight traffic | Throughput and packet loss | Meets defined application requirements |
| Continuous video streaming | End-to-end latency and jitter | Within the project’s video limits |
| Simultaneous-radio operation | Performance of both interfaces | No unacceptable mutual interference |
| Reduced signal conditions | RSSI, SNR, MCS, retransmissions | Defined degradation behavior |
| Different aircraft orientations | Signal quality and video continuity | Meets required operating envelope |
| Extended radio operation | Temperature and supply stability | Within engineering limits |
| Communication interruption | Detection and recovery behavior | Matches the approved system design |
Acceptance limits should be established by the OEM according to the intended mission.
Where telemetry or command-and-control communication performs a safety-related function, the corresponding architecture and failsafe behavior must receive separate validation.
The PX4 Data Links documentation and PX4 Video Streaming guide provide additional technical background for developers working with PX4-based UAV systems.
Can Dual-Radio Wi-Fi 6 Completely Prevent UAV Link Failures?
No wireless platform can guarantee uninterrupted communication under every operating condition.
Dual-independent radios can reduce some forms of traffic contention and provide additional design flexibility.
However, both radios can still be affected by shared system components, software faults, power problems, antenna installation issues, or environmental interference.
Similarly, support for two frequency bands does not automatically provide channel switching, network redundancy, or seamless failover.
Those features depend on the system architecture.
Regulatory requirements also matter. The BlackPepper 6 datasheet identifies support for 4.9 GHz and 5 GHz operation, but availability of those frequencies depends on the relevant jurisdiction and authorizations.
The datasheet lists regulatory compliance as in progress. Claims concerning specific certifications should be independently confirmed for the intended hardware version and deployment region.
For UAV manufacturers, the engineering objective is to reduce avoidable failures, maintain the required application performance, and define safe system behavior when connectivity is lost.
When Should a UAV Manufacturer Consider BlackPepper 6?
BlackPepper 6 is worth evaluating when an embedded UAV platform requires independent wireless interfaces, configurable networking, and high-bandwidth IP communication.
Potential use cases include:
- Industrial inspection UAVs carrying continuous video and operational data
- Aerial asset-monitoring systems with cameras and additional sensors
- UAV platforms requiring separate wireless traffic paths
- OEM systems using Linux or OpenWrt-based network integration
- UAV designs where radio frequency, antenna, power, and mechanical parameters must be evaluated together
The appropriate module depends on the complete aircraft architecture.
A small UAV with limited power and payload capacity may have very different requirements from a larger industrial aircraft carrying several imaging systems.
OEMs should compare the module’s RF specifications, electrical requirements, mechanical dimensions, and available interfaces against the intended platform before selecting it.
Explore BlackPepper 6 BKP6-AX2AX2-2450 Wi-Fi 6 Module
Building More Reliable UAV Communication Systems
Unstable video and telemetry links are not always caused by insufficient radio power or communication range.
Network congestion, RF interference, antenna placement, application bitrate, and processing delays can produce similar symptoms.
The most effective starting point is to identify the cause through measurements and then select an architecture that addresses the actual requirement.
For UAVs carrying continuous video alongside telemetry, independent wireless interfaces can offer greater control over traffic separation and RF configuration.
Vizmonet’s BlackPepper 6 BKP6-AX2AX2-2450 provides a dual-independent Wi-Fi 6 hardware platform with documented RF performance, embedded software support, and industrial integration specifications.
Its value in a UAV application depends on the surrounding network, antennas, software, power system, and validation process.
Need Help Evaluating Wireless Connectivity for Your UAV Platform?
Vizmonet works with OEMs developing embedded wireless systems for demanding industrial applications.
If you are planning a UAV communication architecture or investigating video and telemetry performance, share your intended operating frequencies, link distance, payload bandwidth, antenna constraints, and electrical requirements.
The Vizmonet team can help you evaluate the relevant wireless hardware and integration requirements.
Frequently Asked Questions
Why does UAV video freeze while telemetry still works?
Video generally consumes more bandwidth than telemetry. When wireless capacity decreases because of interference, packet retransmissions, or poor signal conditions, video performance may deteriorate while the lower-rate telemetry stream continues operating. Encoding, buffering, and decoding problems can cause similar symptoms.
How can dual-radio Wi-Fi 6 improve UAV communication?
Dual-independent radio interfaces allow engineers to configure separate network paths for different applications. This may reduce direct traffic contention and improve frequency-planning flexibility when the network is designed and tested appropriately.
Does BlackPepper 6 support simultaneous 2.4 GHz and 5 GHz operation?
The BKP6-AX2AX2-2450 datasheet identifies a dual-independent 2×2 MU-MIMO architecture with separate 2.4 GHz and 4.9/5 GHz radio paths. The final simultaneous-radio configuration should be verified against the intended software and system requirements.
What causes poor video throughput even when the received signal is strong?
A strong received signal does not guarantee a clean wireless channel. Interference, high airtime utilization, retransmissions, network congestion, and application-processing limits can reduce effective video throughput.
What is the operating voltage of BlackPepper 6?
The datasheet specifies a 9–30 V DC input. It also lists 21 W total DC power consumption, excluding the USB add-on, in its general specifications.
What antennas does the BKP6-AX2AX2-2450 use?
The module has four SMA female antenna connectors. Two are assigned to its 4.9/5 GHz radio and two to its 2.4 GHz radio. Antenna selection and installation must be evaluated for the intended aircraft and operating frequencies.
Does BlackPepper 6 automatically switch to another radio if one link fails?
The datasheet documents independent radios but does not establish automatic failover functionality. Switching, recovery, and application continuity require appropriate system software and validation.
Is BlackPepper 6 suitable for every UAV?
No. Its suitability depends on the aircraft’s power budget, payload capacity, available mounting space, antenna installation, thermal conditions, software integration, and regulatory requirements. OEMs should evaluate these factors before adoption.
What should engineers test before deploying a UAV wireless communication system?
At minimum, test sustained throughput, latency, jitter, packet loss, antenna performance, RF interference, simultaneous-radio behavior, power consumption, thermal stability, and recovery from connection loss. The results should be evaluated against mission-specific acceptance criteria.